Spranic's Spatial Memory Layer Aims to Give Robots Context for Adaptive Tasks
Munich startup Spranic is developing a spatial memory system that records how physical environments change, helping robots understand their surroundings across multiple tasks through knowledge graphs.
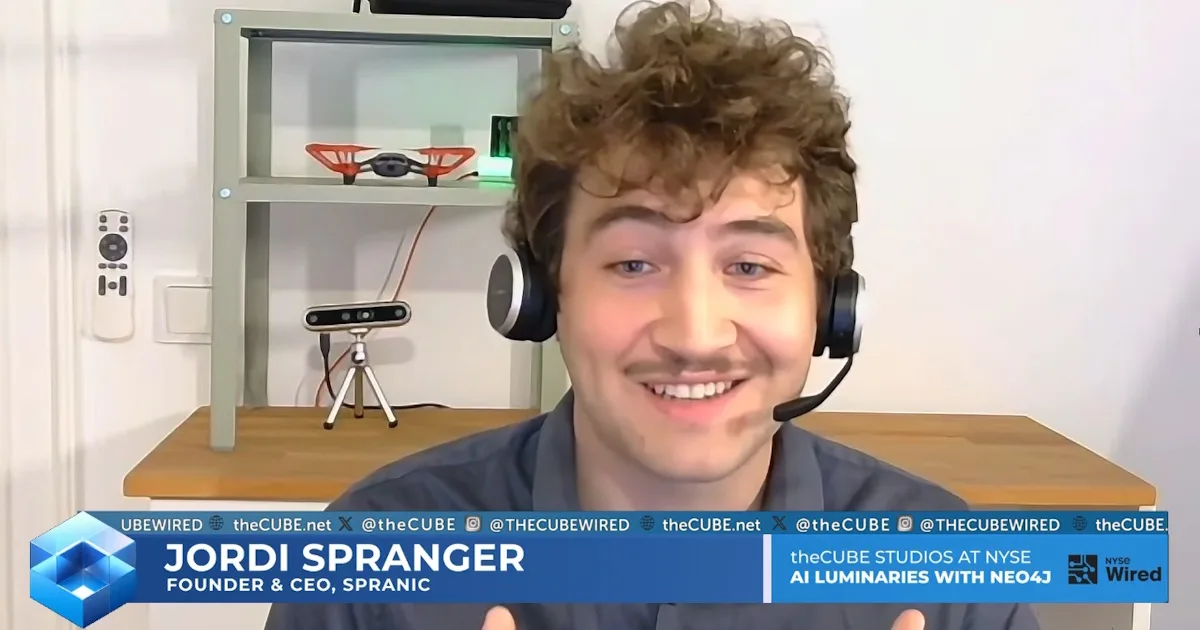
For physical AI systems to move beyond rigid, preprogrammed behaviors, they require awareness of their physical surroundings. Spranic, a Munich-based company, is constructing a spatial memory framework designed to capture physical spaces and track their evolution. By integrating this capability with knowledge graphs, the technology could enable robots to comprehend their environments in ways that transfer across different applications, according to Jordi Spranger, the company's founder and chief executive officer.
Robots deserve the right context at the right time across domains. This is the problem we're tackling. We can see that this works really well for digital agents already. Now we're bringing this to the physical world.
Jordi Spranger, founder and CEO of Spranic
Spranger shared these insights during an appearance on theCUBE Research's John Furrier for the theCUBE + NYSE Wired: AI Luminaries interview series, broadcast on theCUBE, SiliconANGLE Media's livestreaming platform. The discussion centered on how knowledge graphs might enable robots to adjust their operations to new tasks while maintaining transparency in their decision-making processes.
Giving physical AI reusable context
One persistent obstacle in physical AI development is adapting machines to shifting environments. According to Spranger, reusable spatial context can minimize the amount of task-specific planning needed when deploying robots.
But for robots, maps are a really big part. [Robots] need Google Maps on steroids to be really free from a statically planned task [so they] can replan across a lot of tasks that a humanoid could do.
Jordi Spranger
Achieving this flexibility also demands that robots understand the provenance of their information—where the data originates. Knowledge graphs excel at linking relevant sources while maintaining this lineage of information, Spranger explained.
https://www.youtube.com/embed/ukHYH3-yeik?feature=oembed
At the end of the day, a lot of domains have to come together and graphs are really good at connecting domains. Robots … act in a huge variety of different scenarios. They need to have the right information sources, provenance as well, and work in an auditable way, in a safe way. Graphs provide the flexibility to connect data sources that are needed and remove data sources that are not needed.
Jordi Spranger